Listen to this content
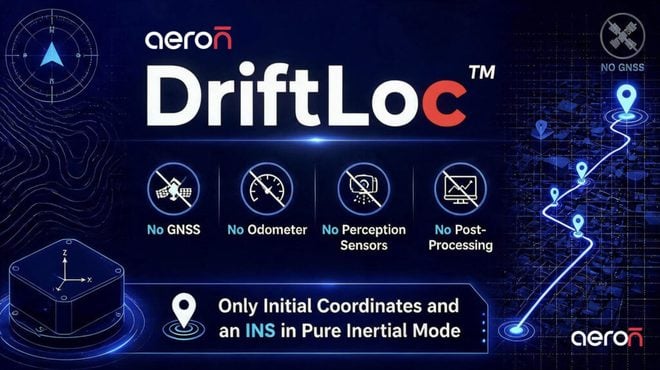
Aeron Systems has launched DriftLoc, a navigation algorithm designed to deliver reliable inertial positioning for extended periods without access to GNSS.
The technology addresses a fundamental challenge facing modern navigation systems, where position accuracy can rapidly degrade when satellite signals are blocked, disrupted or deliberately jammed.
DriftLoc uses real-time algorithms to estimate and continuously correct changing sensor errors. Designed to run on an inertial measurement unit (IMU) and modest embedded processor, the technology combines a physics-driven kinematic model with Bayesian estimation and statistical signal processing.
Rather than relying solely on raw accelerometer and gyroscope measurements, DriftLoc continuously evaluates the platform’s motion and uses its behavior, including acceleration, deceleration, stationary periods, turning and settling, to establish mathematical correlations and identify errors as they develop. This allows the system to maintain a statistically weighted estimate of sensor reliability and continuously refine the inertial position solution in real time.
The technology has been demonstrated on Aeron Systems’ compact MEMS-based PLX3-N inertial navigation system. During a van-based test, the PLX3-N was operated without a GNSS antenna. Following a 30-second static alignment period, initial coordinates were supplied through the user interface from a GNSS-aided reference system installed separately for comparison.
The PLX3-N subsequently generated a clean, pure-inertial-derived position solution in real time, demonstrating DriftLoc’s ability to maintain positioning when GNSS is unavailable.
By shifting the focus from increasingly sophisticated inertial hardware to advanced real-time estimation, DriftLoc is intended to provide near-navigation-grade positioning performance with low weight and cost.